Every step gives energy back.
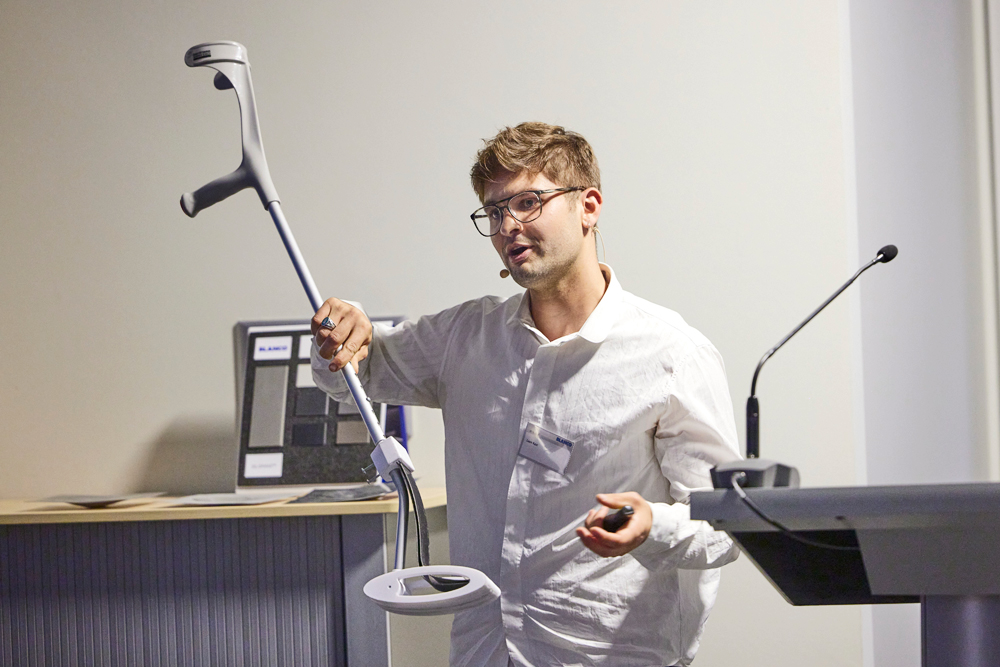
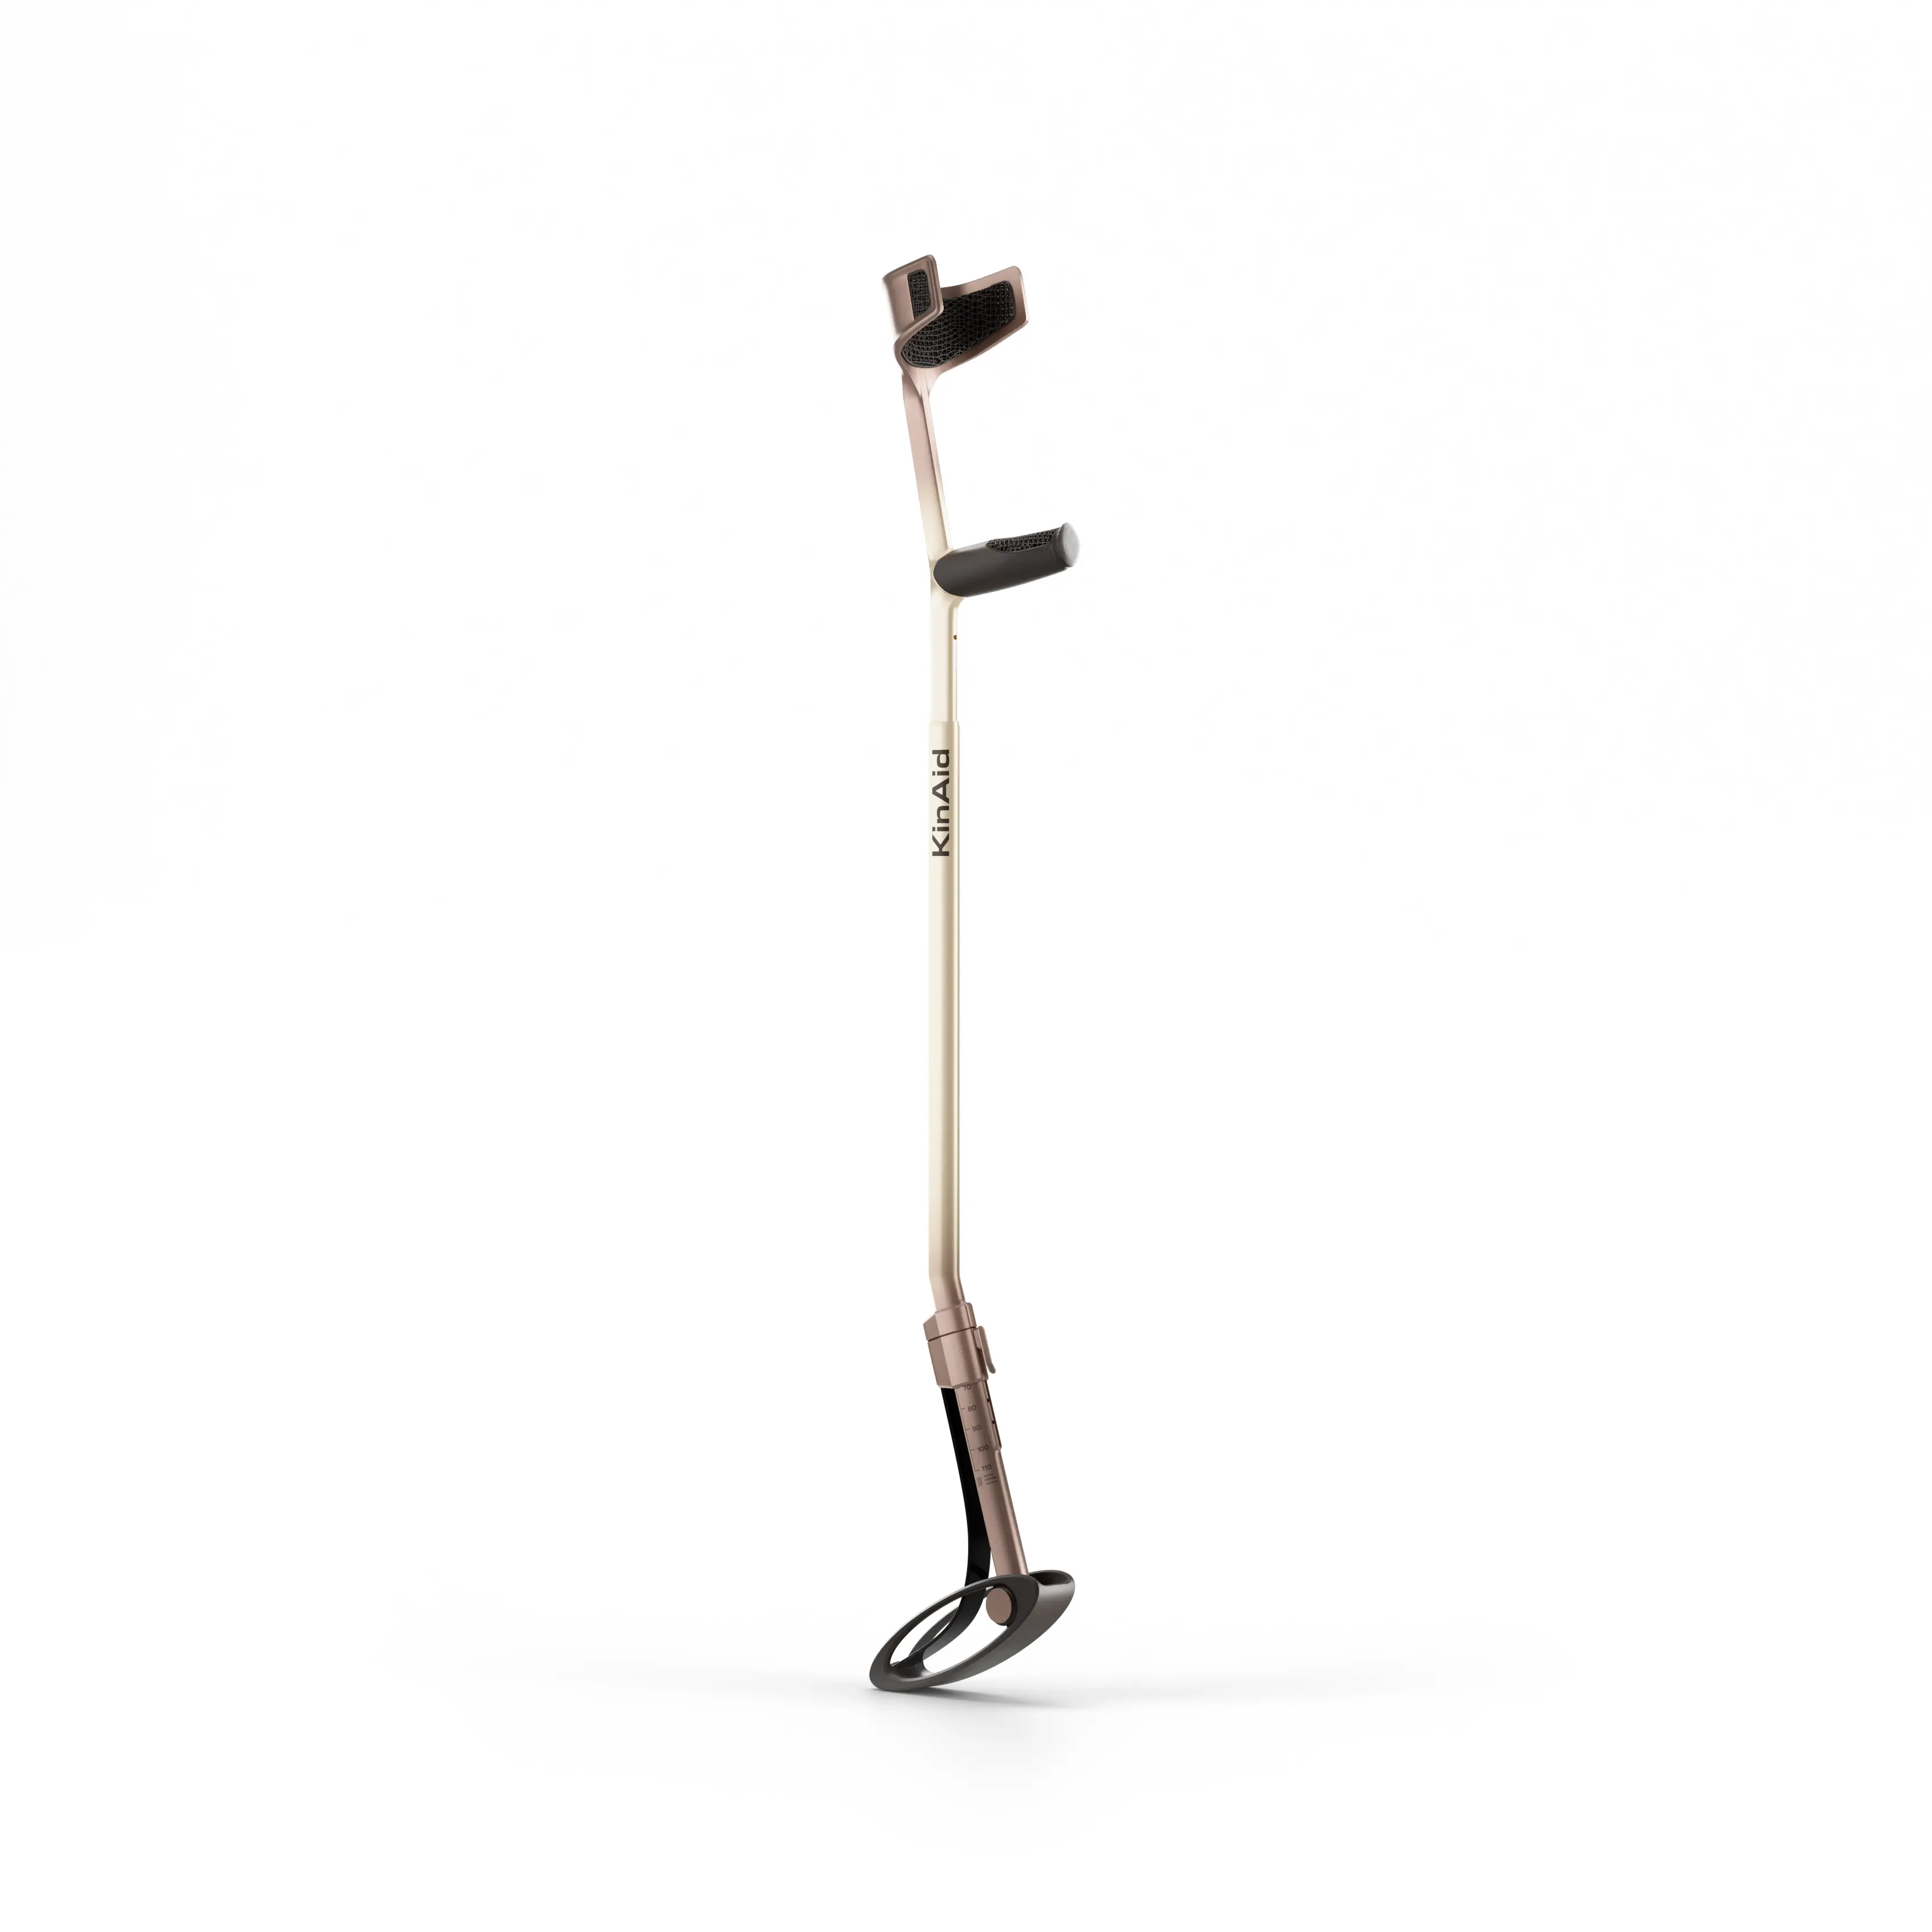
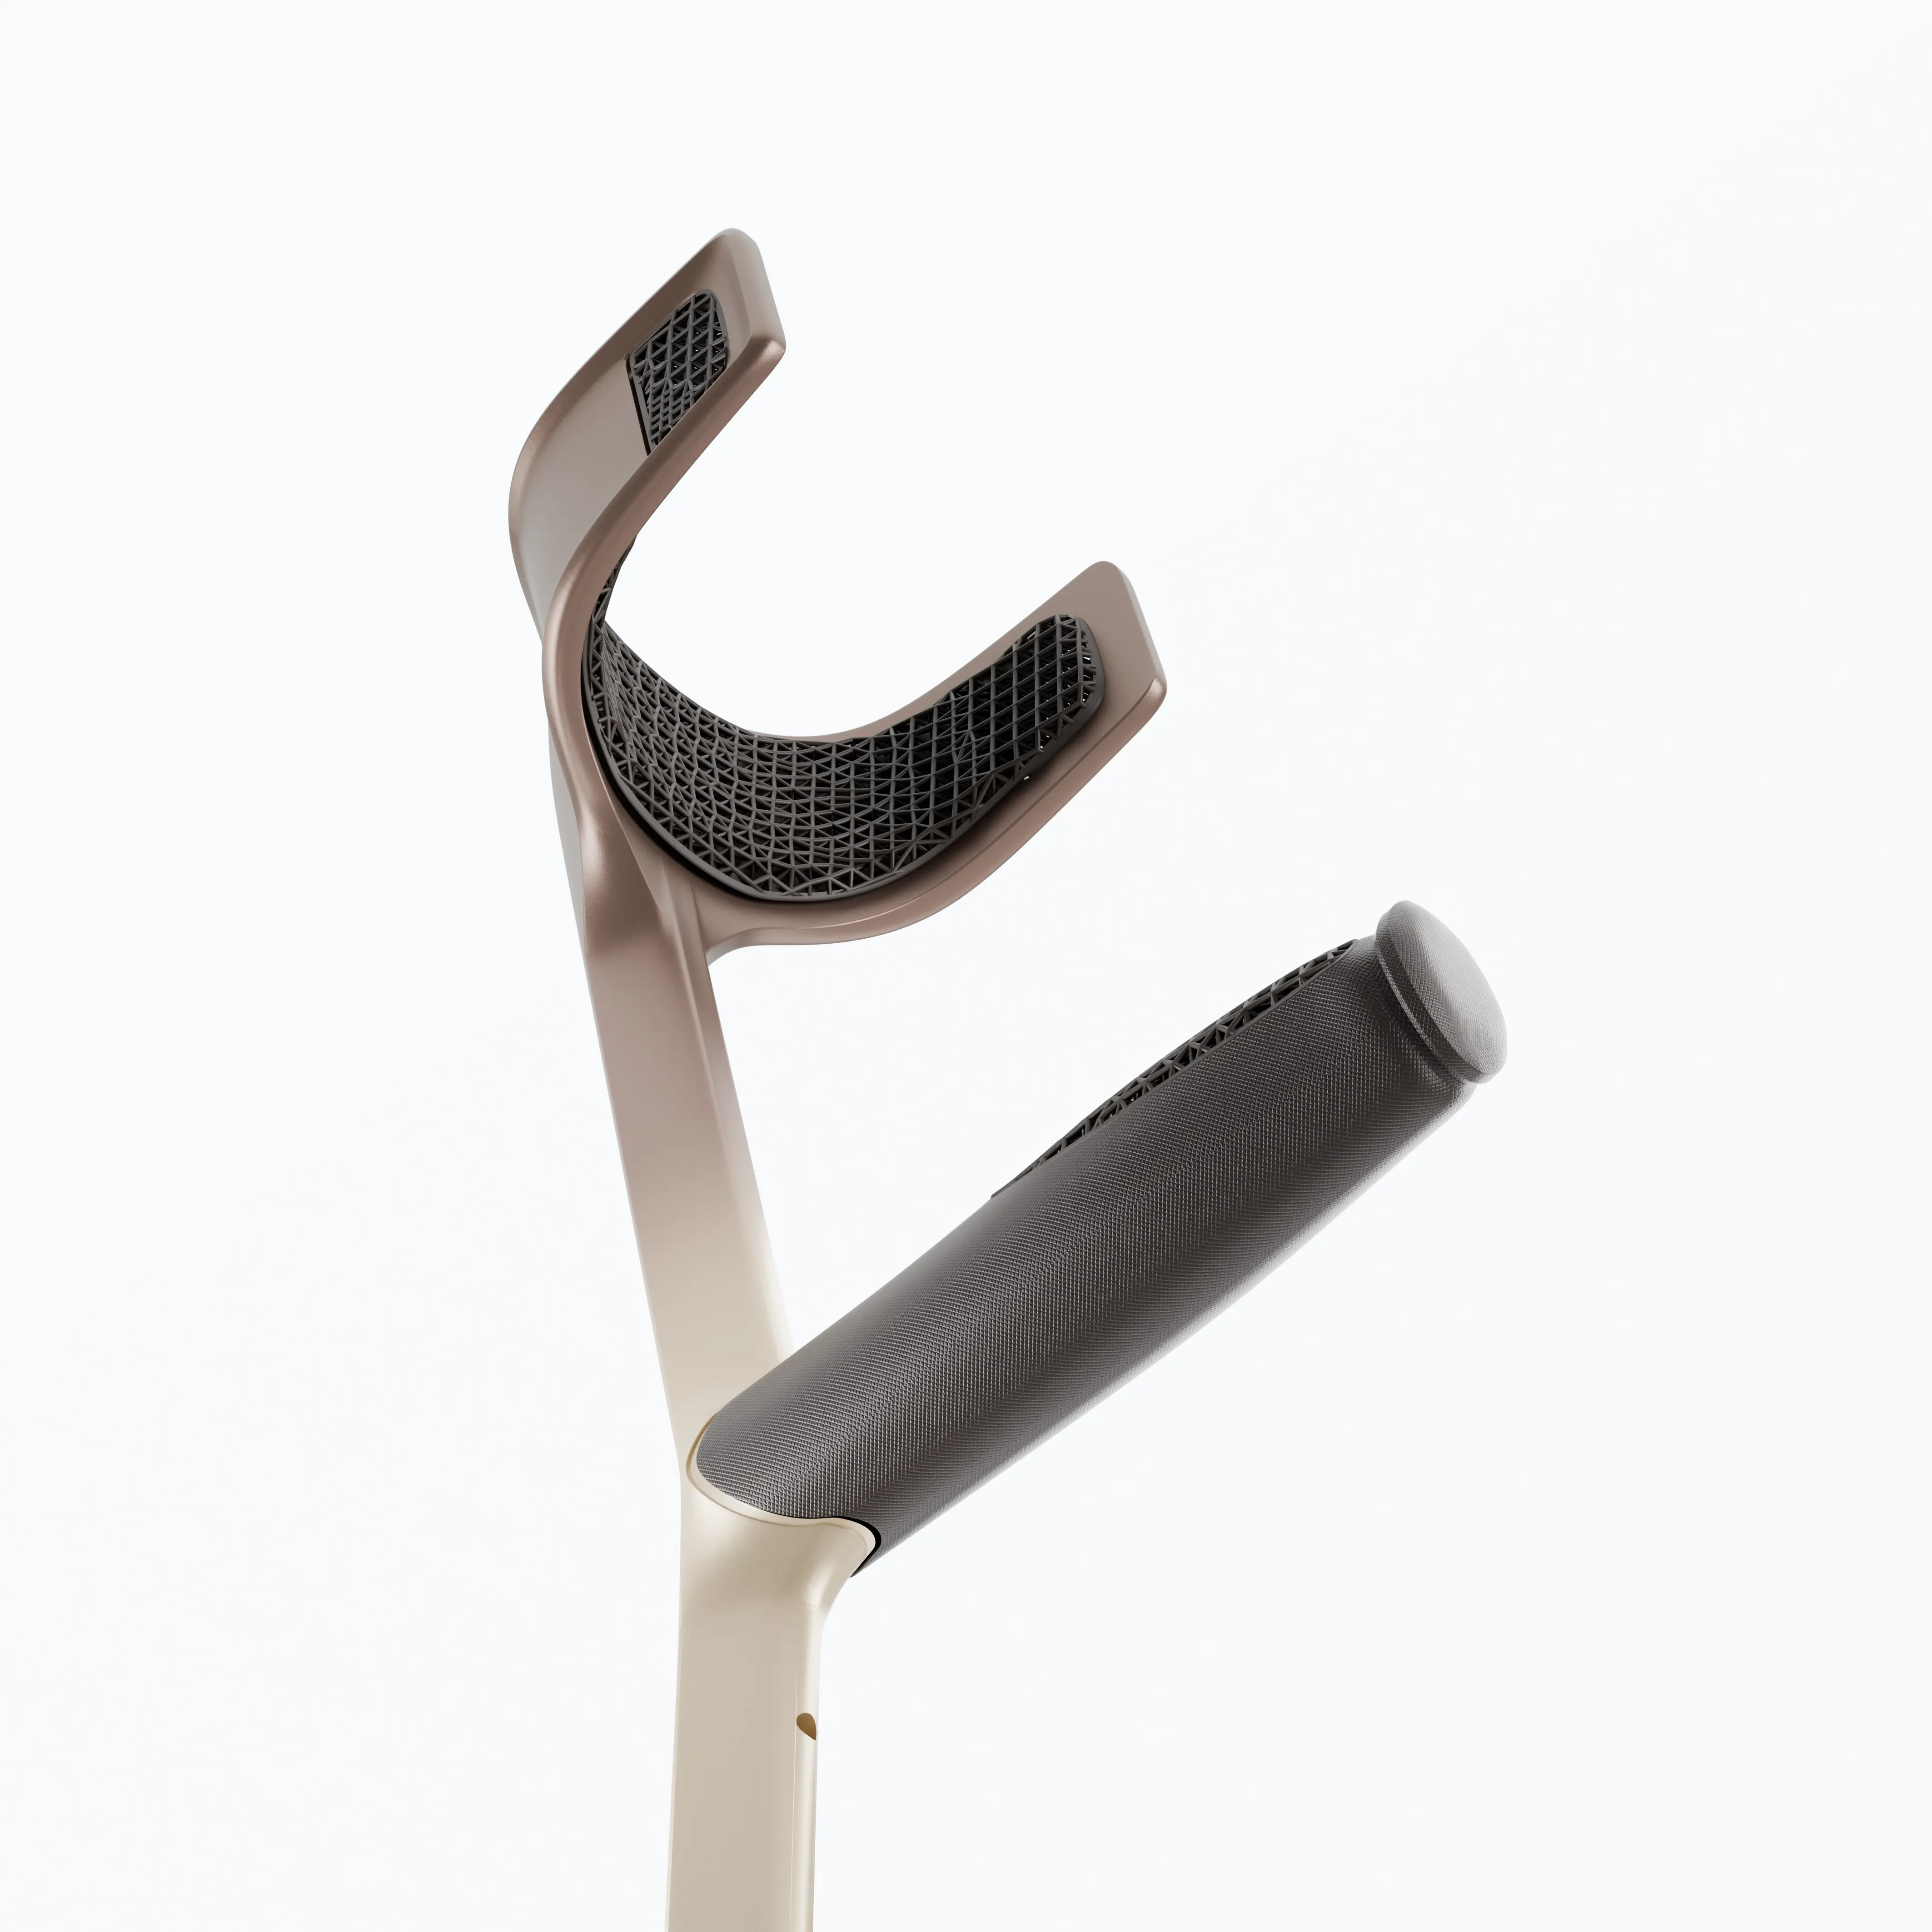
The KinAid crutch brings carbon spring technology from sports prosthetics to the forearm crutch.
Meet us at MEDICA 2026
on 19 November 2026

The problem
Conventional crutches are rigid.
- 01
The force crutch users put into planting and leaning on the crutch is lost. Walking with forearm crutches can take two to three times as much energy as normal walking.
- 02
The unsprung impact with the ground has to be absorbed directly by the joints in the shoulders, wrists and arms.
Patent pending
Our principle.
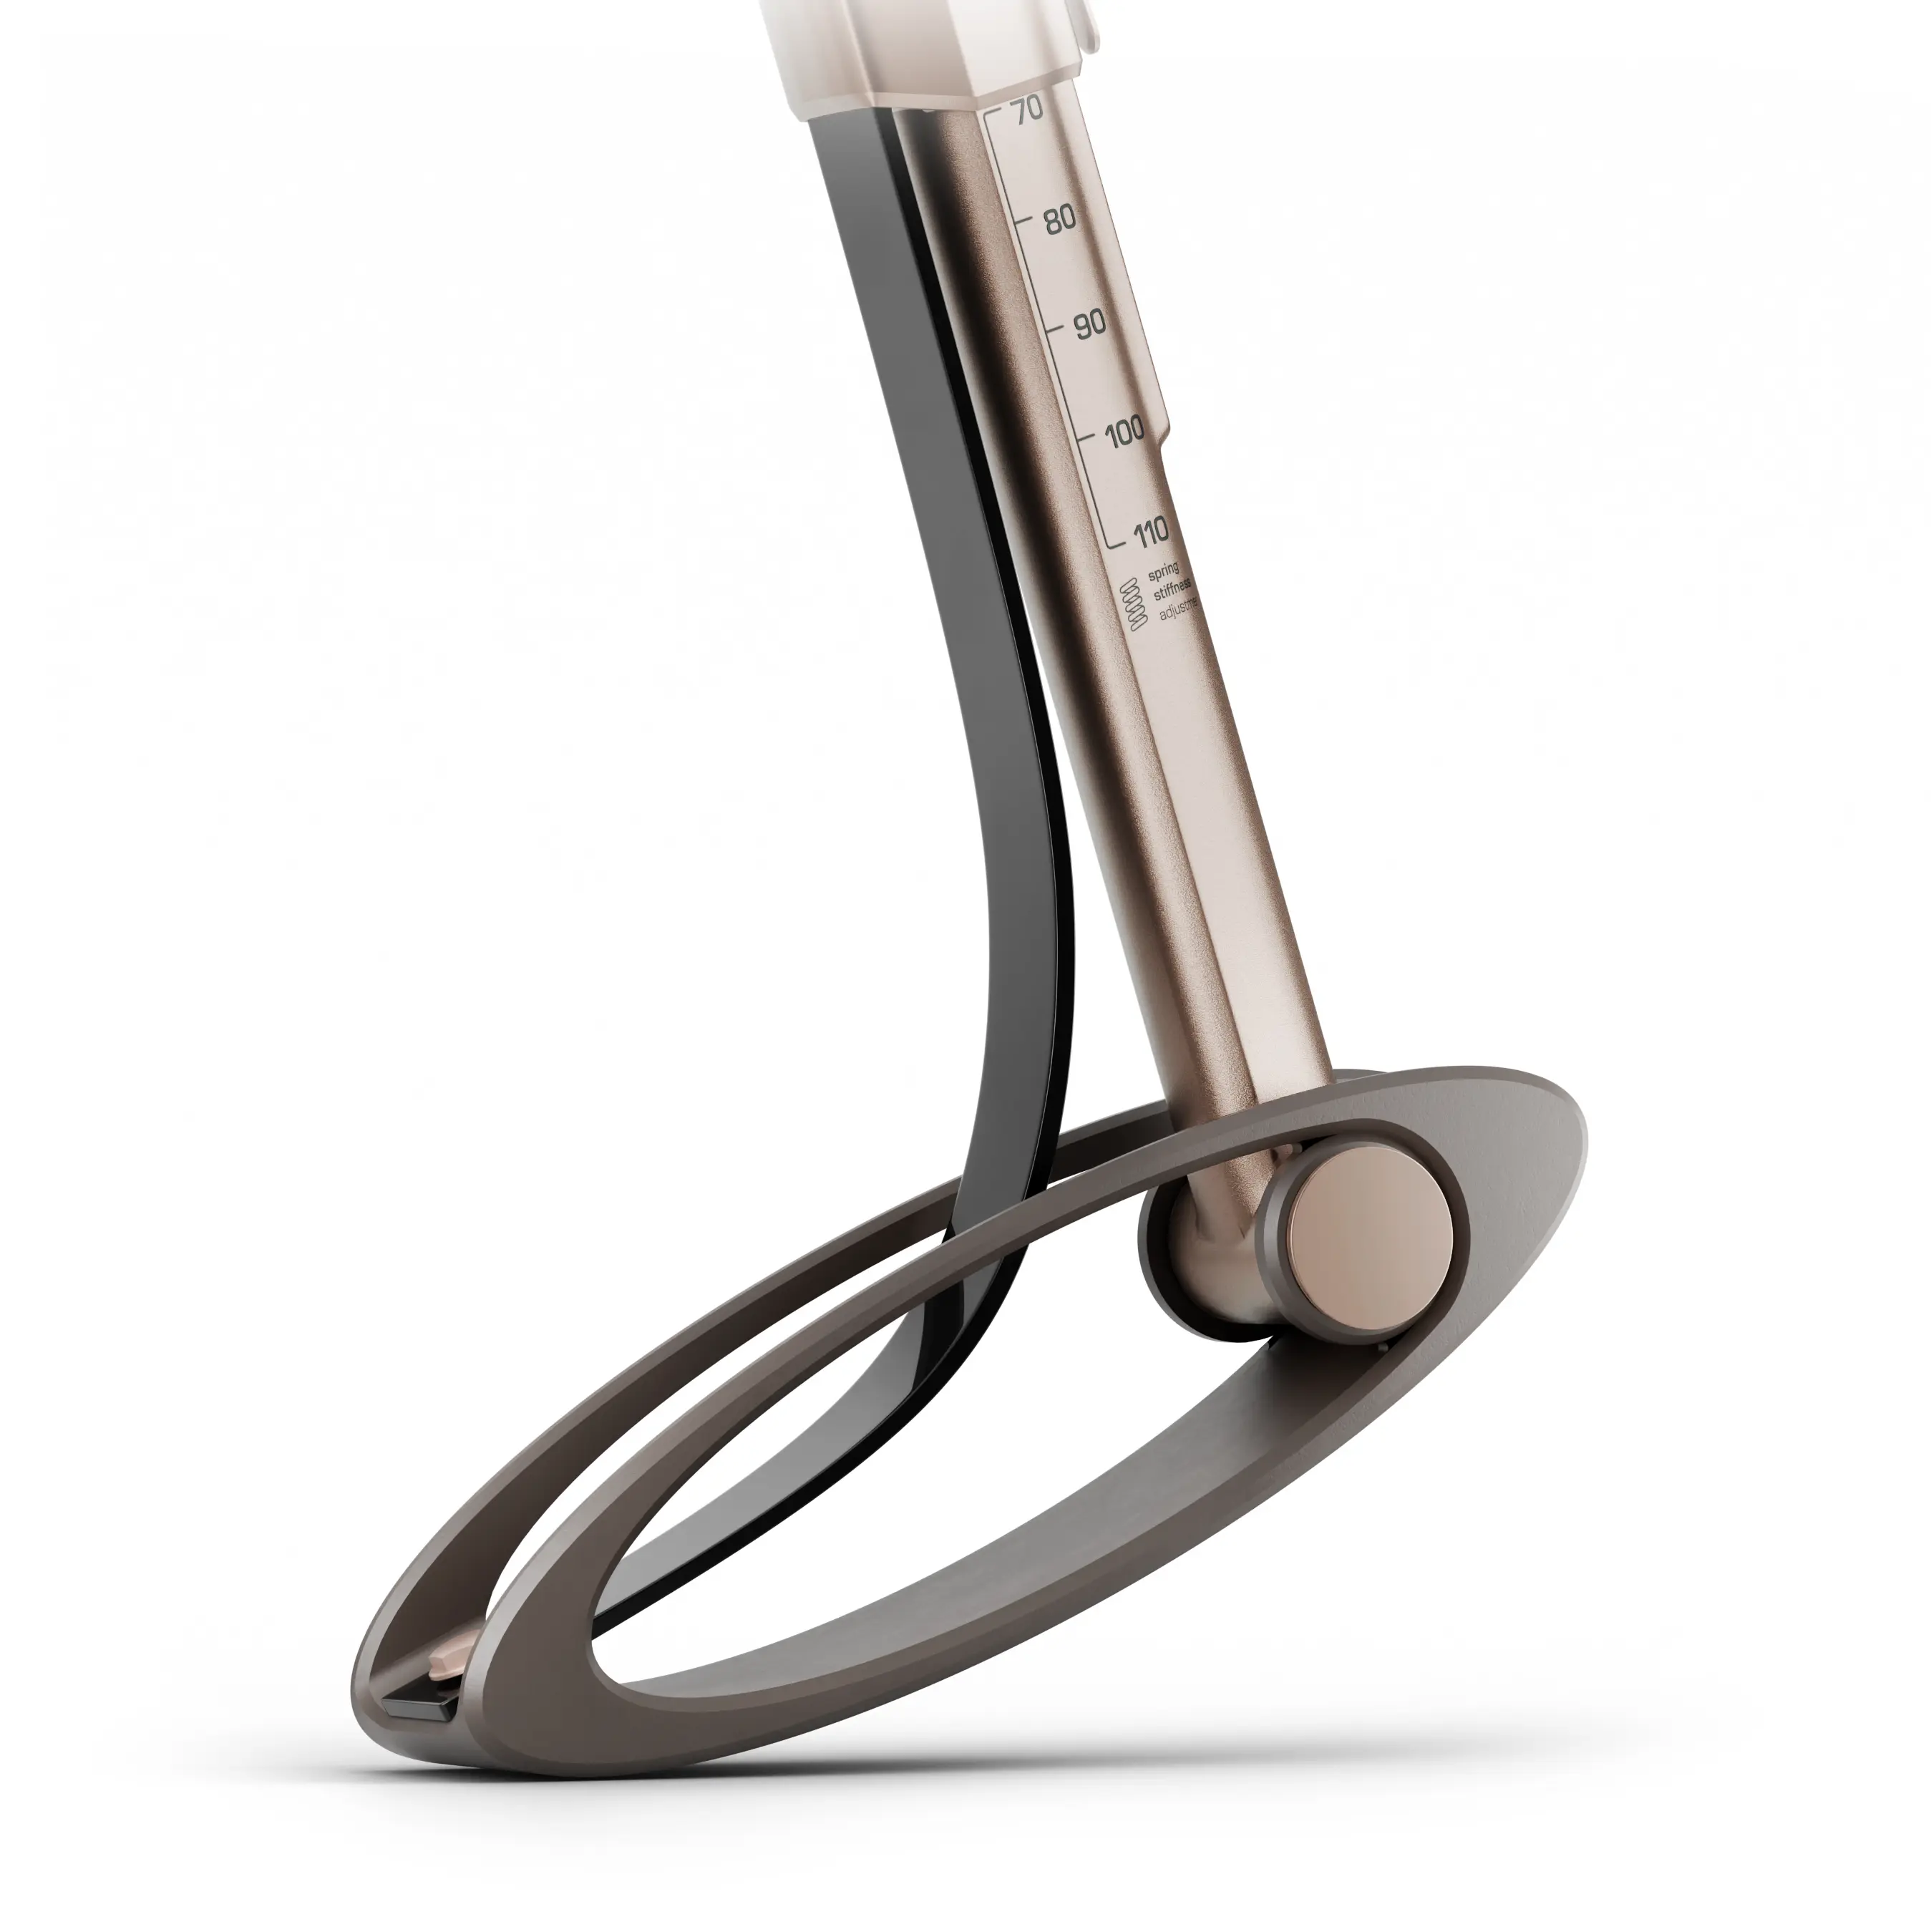
An inverted rollover geometry recreates the natural motion of the foot. The carbon spring stores energy as the crutch is planted and releases it on push-off.
Move the orange circle.
The carbon spring absorbs the energy on ground contact.
The spring cushions and stores kinetic energy.
The spring returns the energy to the person using the crutch.
Design
The key features of our prototype
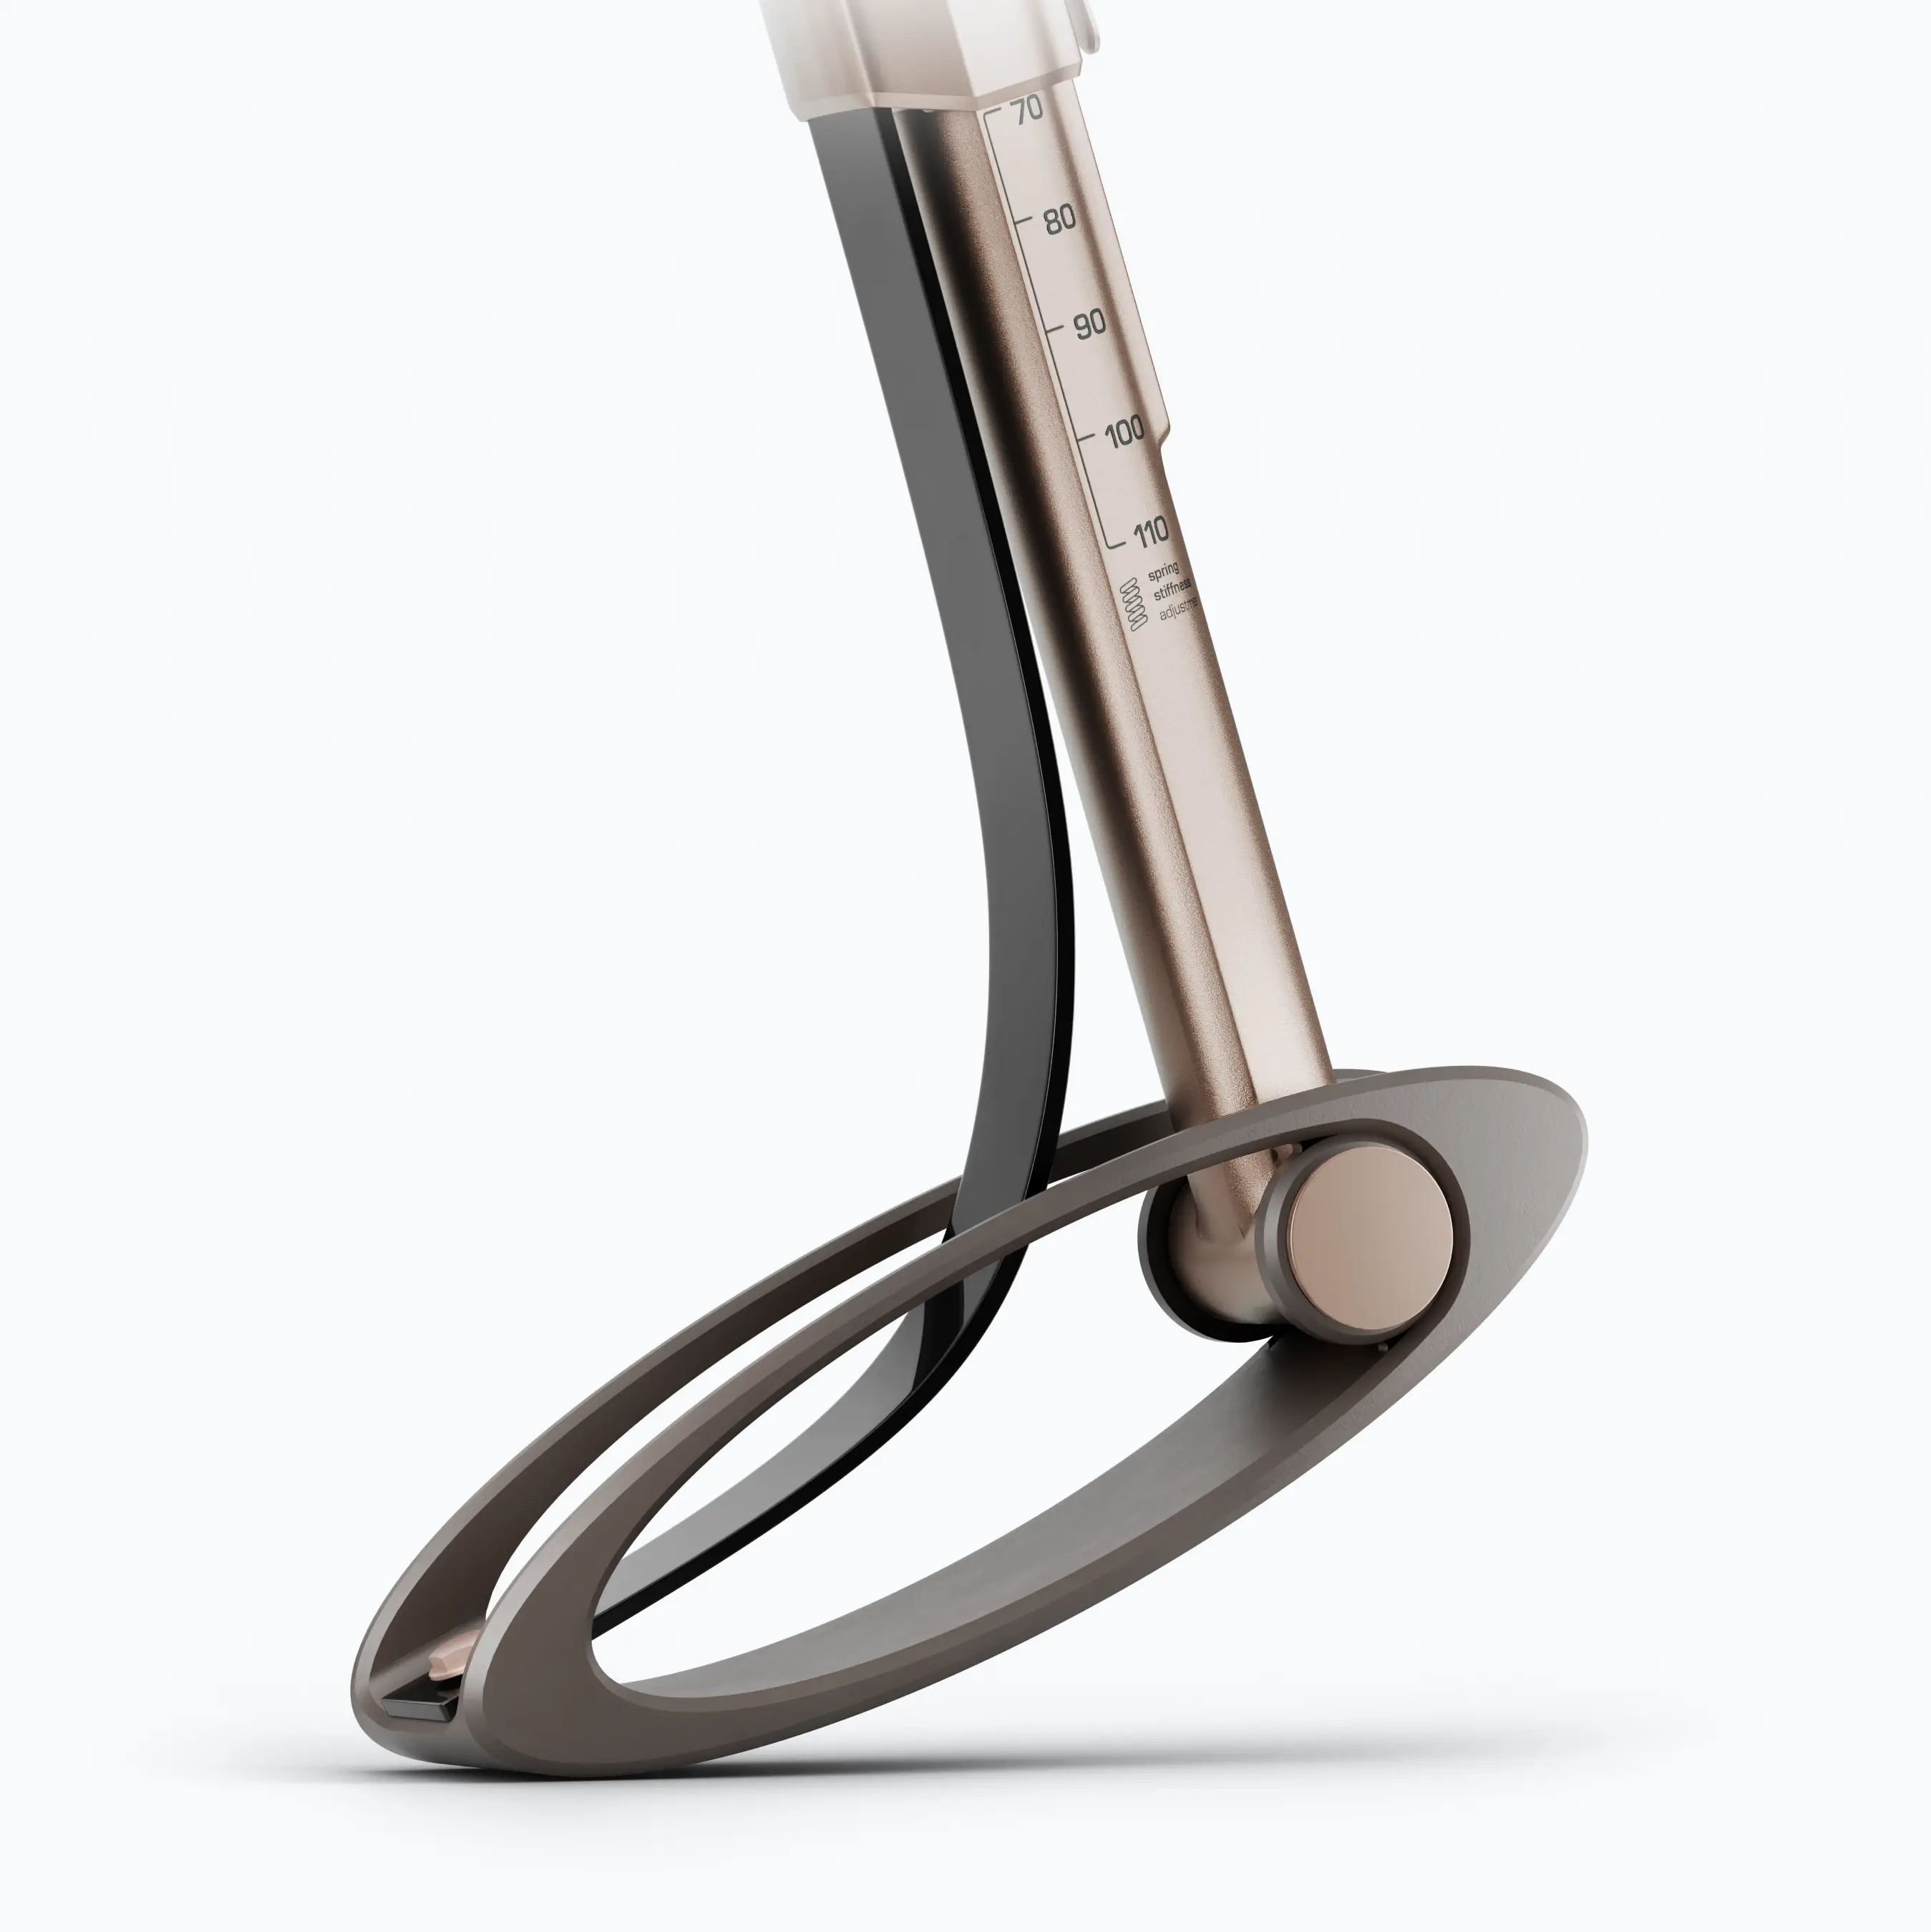
Rollover foot
Rolls off like a foot instead of landing on a single point.
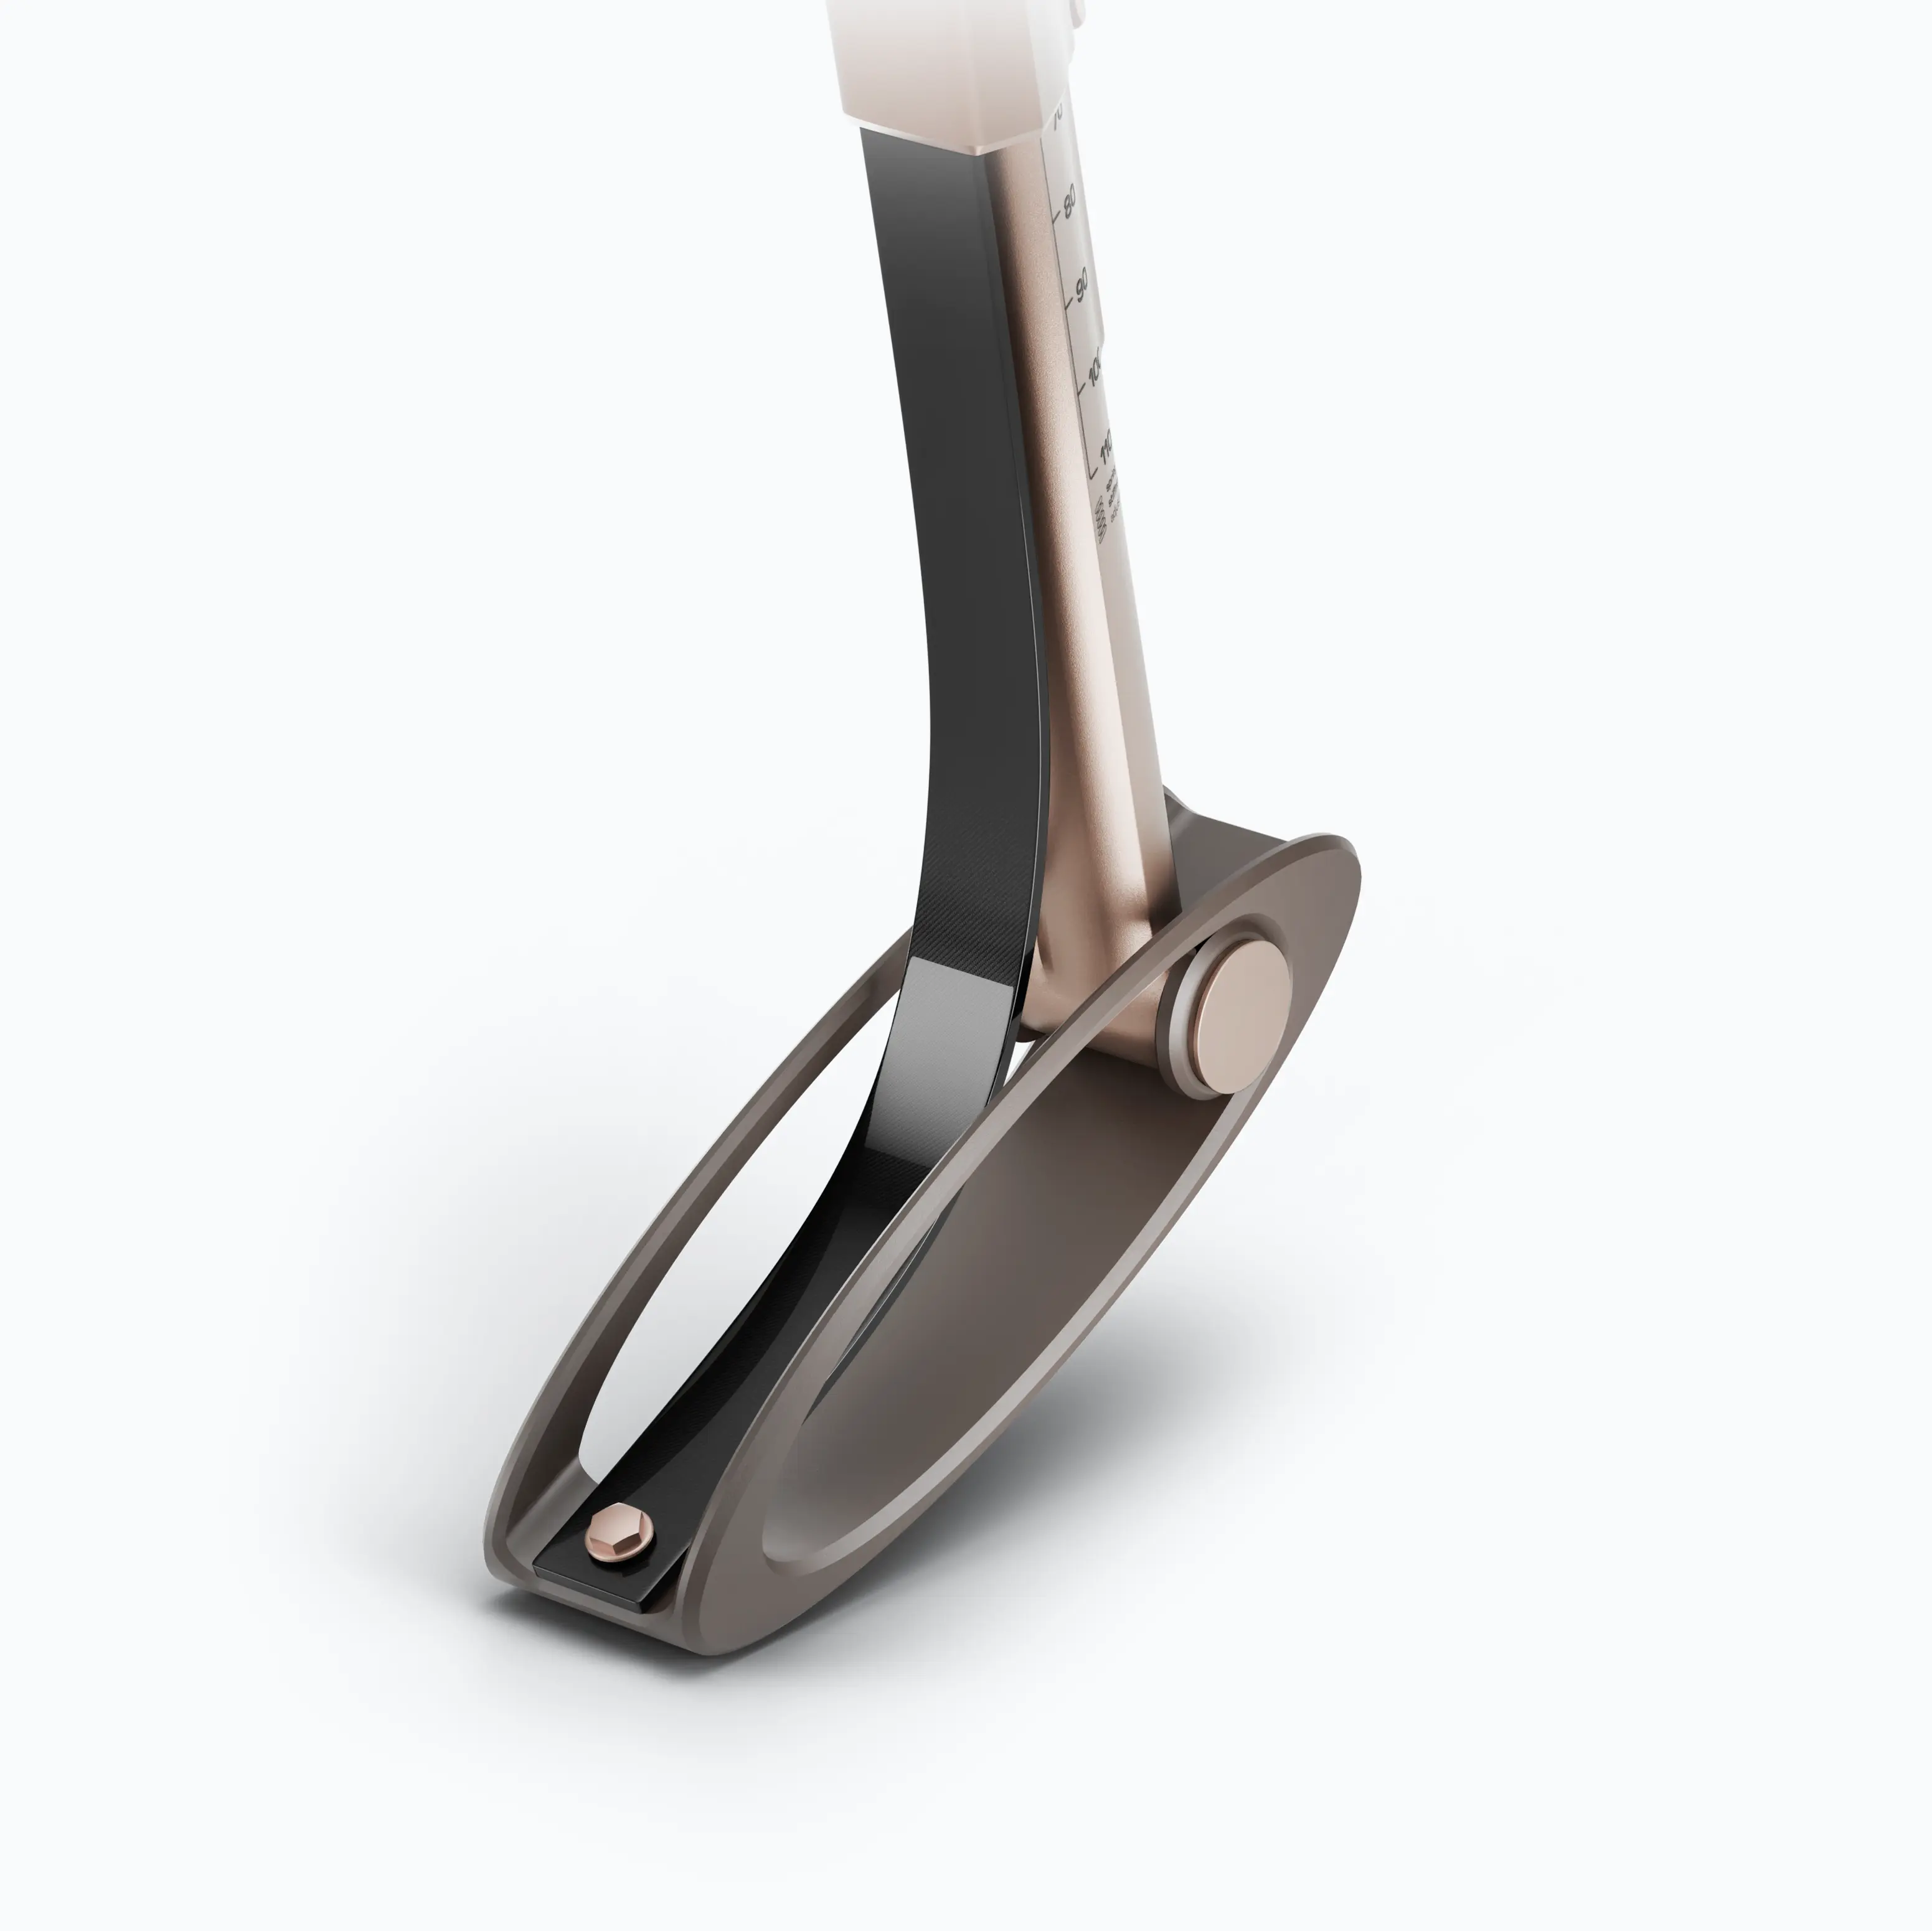
Carbon spring
The heart of it – a technology from sports prosthetics.
Adjustable spring clamp
Spring force adapts to the stage of recovery and the user
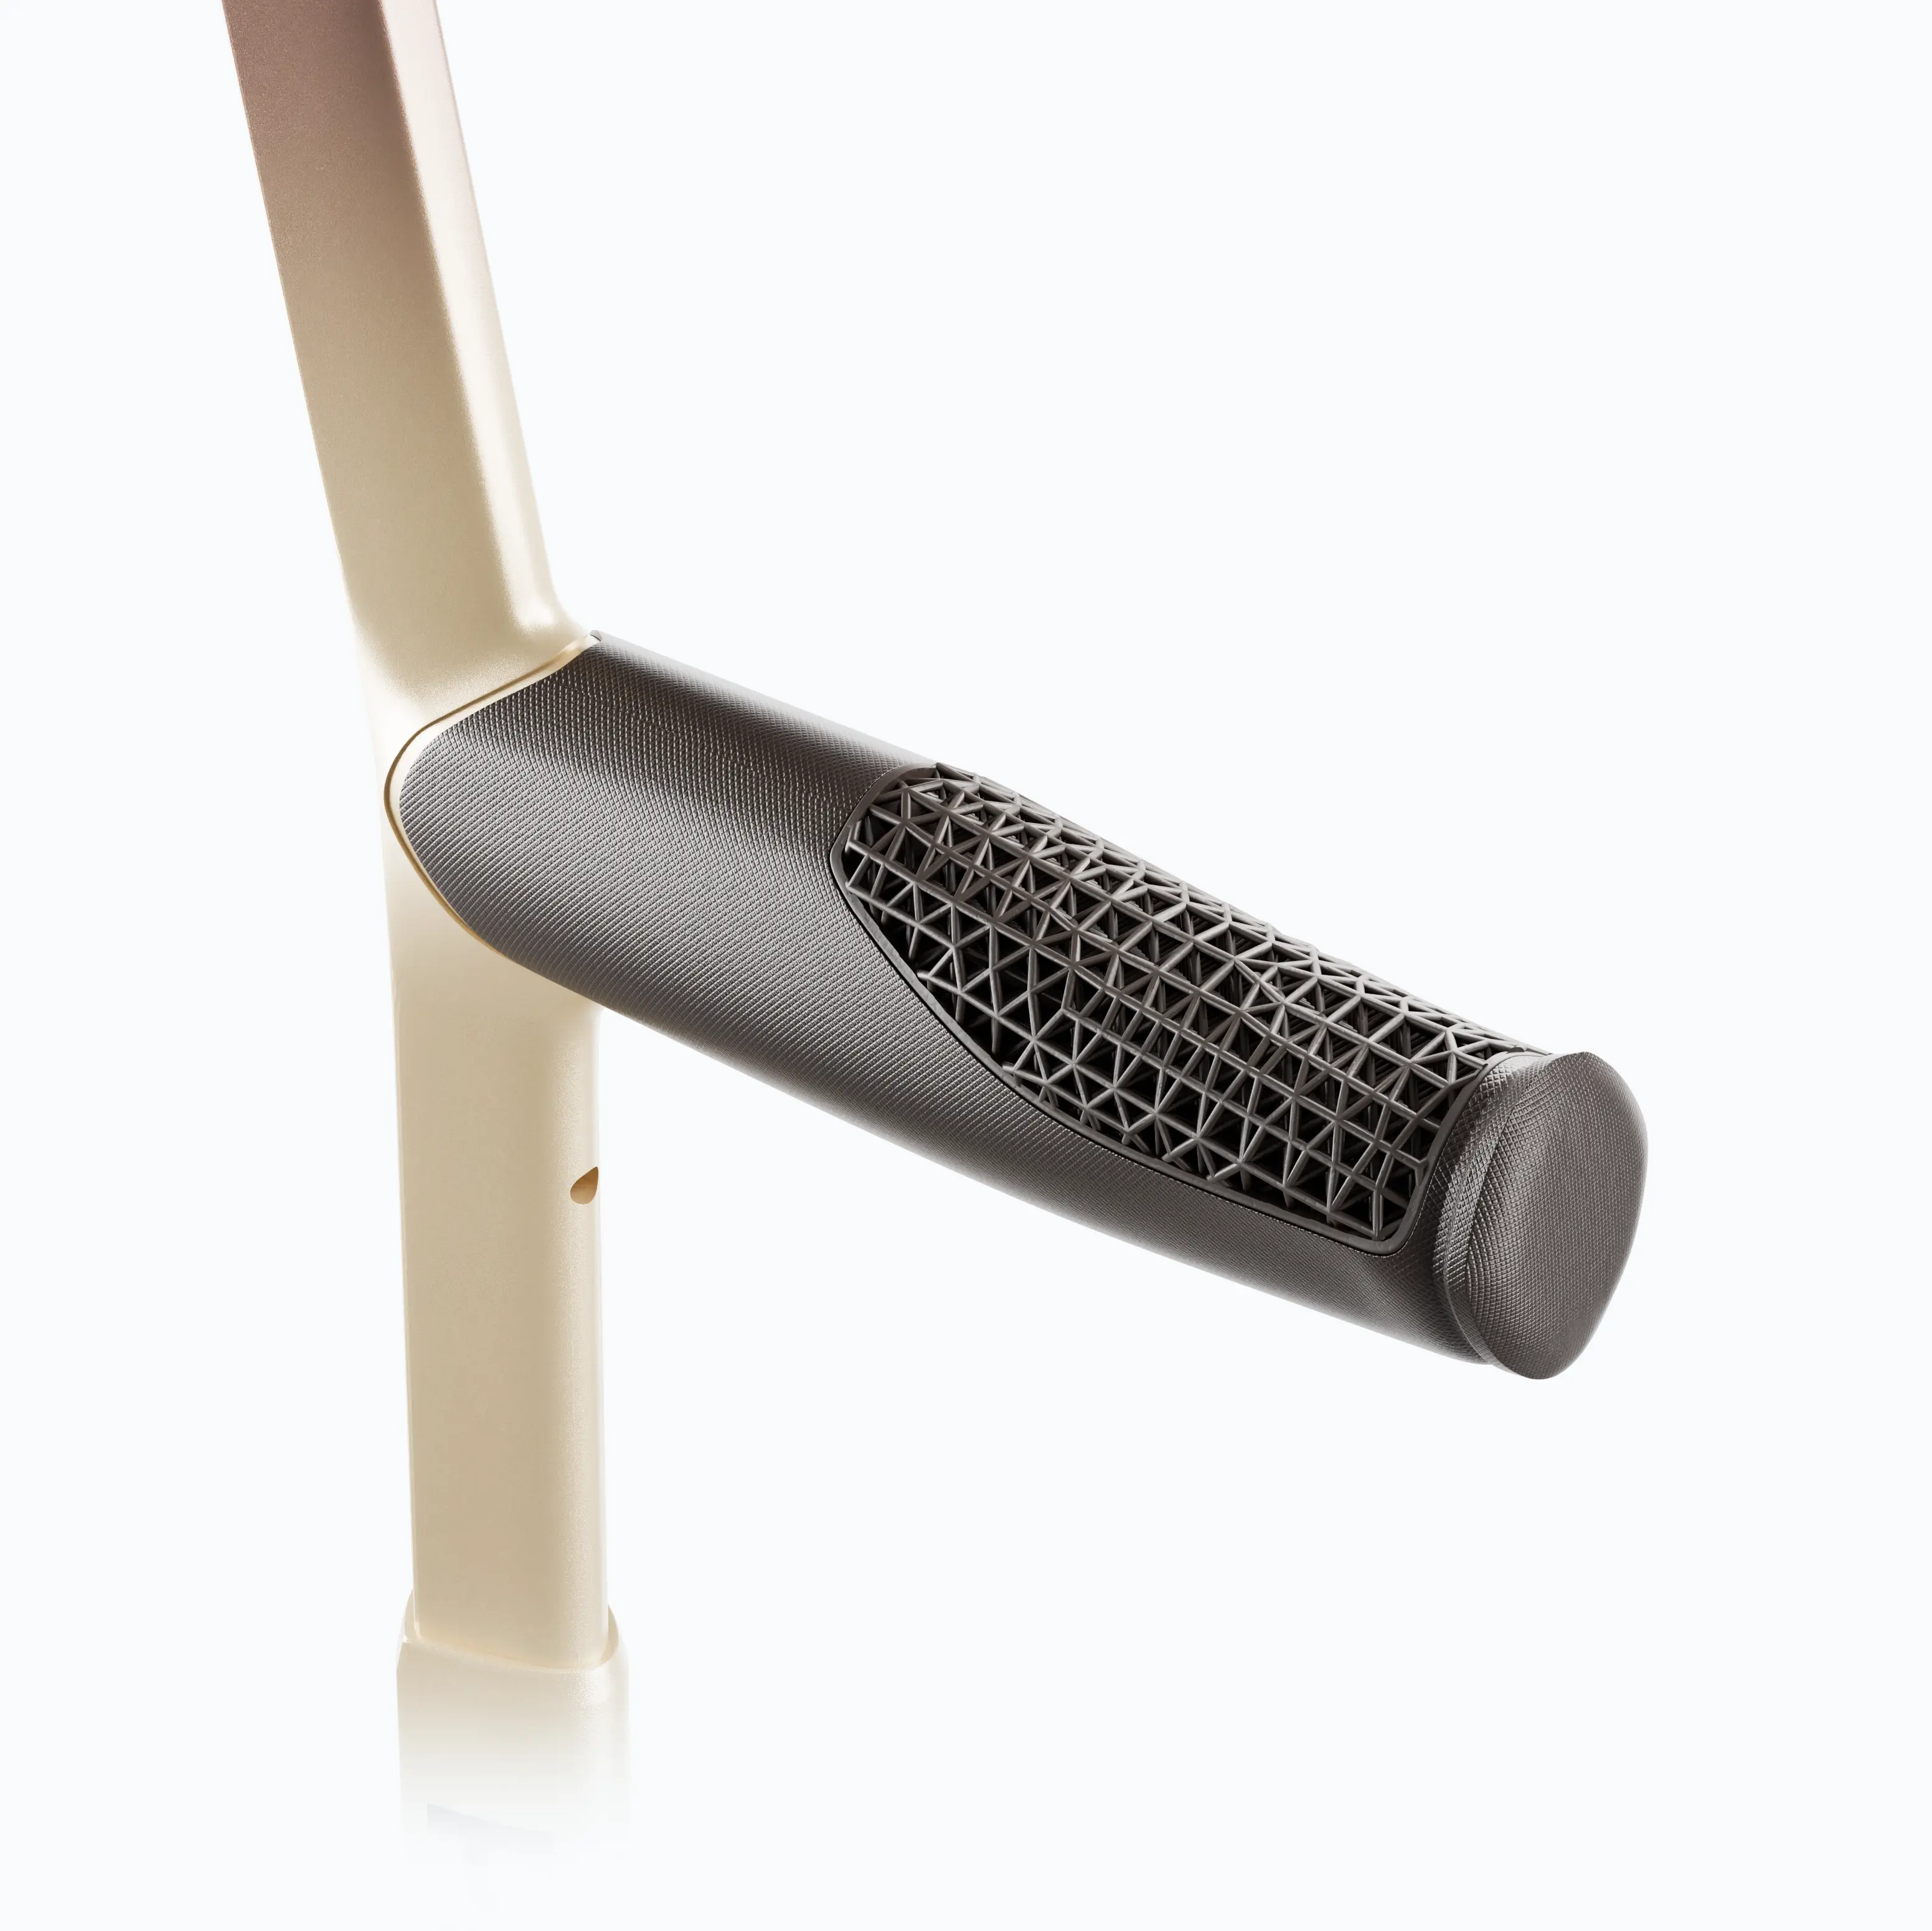
Lattice grip
3D-printed lattice structure for an ergonomic hold.
Follow our development
Our email newsletter keeps you up to date exclusively on the development of our prototype. Updates at most once a month.

Current roadmap
01.01.2025
Bachelor’s thesis (Pforzheim University)
01.01.2026
Witzenmann GmbH – Sponsorship award
02.12.2026
Rolf Scheuermann Foundation – Special prize
2026
Heinrich Blanc Sponsorship Award – Winner 2026
RIMOWA Design Prize – Semifinalist
01.01.2026 – today
Prototyping and CAD development
01.01.2026 – today
Visiting MEDICA
upcoming
Testing
upcoming
Industry and development partners
upcoming
Funding
Team